Two co-authored papers, BEAKER and FluxFlow, were accepted by NeurIPS 2026.
Frankie Dong Li
I'm a Graduate Student at Macau University of Science and Technology (MUST) and the Institute of Automation, Chinese Academy of Sciences (CASIA), supervised by Prof. Long Chen and Prof. Fei-Yue Wang.
Research
My current research focuses on robotics and AI for space exploration, particularly how AI can accelerate planetary exploration.
Leadership & Community Contributions
Dong Li actively contributes to the robotics and space robotics communities. He co-organized the Special Session on Robotics for Space Exploration at IROS 2026 and maintains awesome-NeRF-and-3DGS-SLAM 


Latest news
Our OpenSpaceLab won 1st place (Single-Robot Public Track) and 3rd place (Single- & Multi-Robot Private Tracks) in the IROS 2026 Autonomous Exploration Challenge! More details can be found on GitHub.
Two papers He3-Seeker and OS-Rover have been accepted by iSpaRo 2026. See you in Cologne this November!
The co-author work SpikeVLA and Denoising the Deep Sky have been accepted by ICML 2026 and ECCV 2026 respectively.
Invited as a reviewer for IEEE Transactions on Robotics (T-RO).
Attending ICRA 2026 (Vienna). Looking to connect on Space Robotics, Field Robotics, SLAM, and Autonomous Exploration.
Invited to review 2 manuscripts for The International Journal of Robotics Research (IJRR).
我们合作的综述论文 机器人灵巧手:迈向通用操作的关键技术 被中国图形图形学报接收.
We are organizing the Special Session “Robotics in Space Exploration” at IROS 2026. More information can be found here.
GauSem-SLAM has been accepted by ICRA 2026. See you in Vienna!.
Our survey on 3D Scene Representation is available on arXiv, and Chinese introduction available for 机器之心.
I will travel to Hangzhou, China to attend IROS 2025.
The co-author work GaussR-SLAM has been accepted by RAL~
SLAM-X and Wild3A have been accepted by ACM MM 2025!
TWC-SLAM and STG-Avatar have been accepted by IROS 2025~
The co-author work GARAD-SLAM has been accepted by ICRA 2025.
The star count of our awesome-Implicit-NeRF-SLAM repository has reached 1K!
I have received the RAS travel grant and will travel to Abu Dhabi, UAE to attend IROS 2024.
UMAD has been accepted by IROS 2024! Thanks to everyone who participated in this project!
Selected work
Research and projects
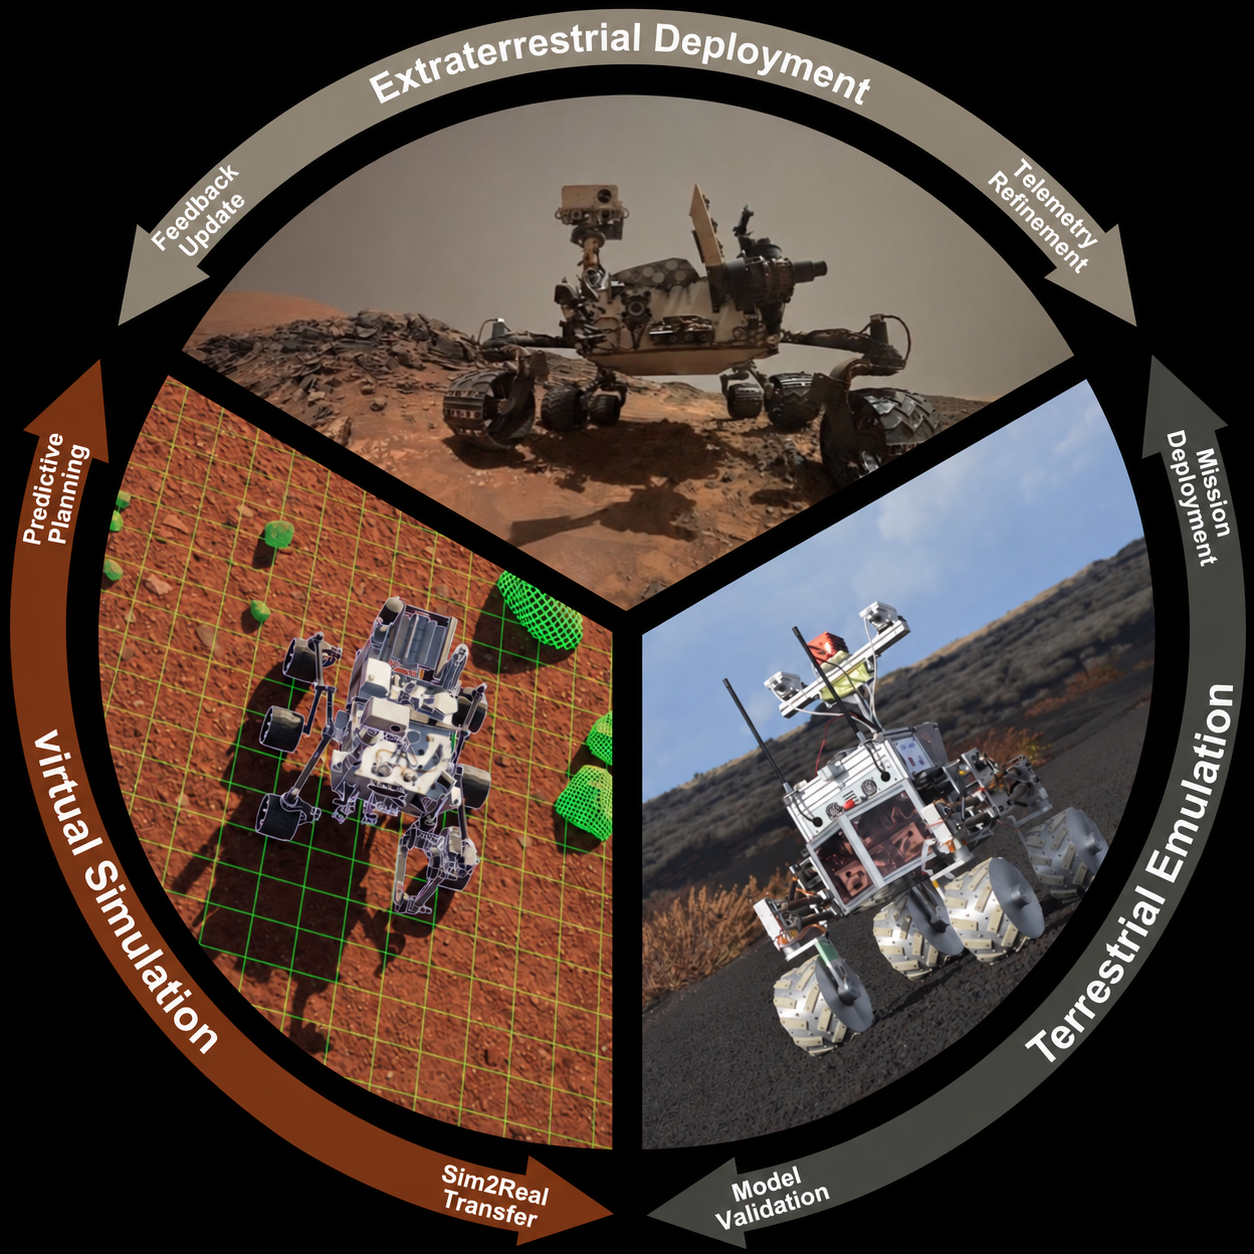
Mining beyond Earth with Space Robots: Exploration, Sampling, and Extraction
Dong Li, Dujun Nie, Xiaotong Zhang, Ruilin Wang, Yuchen Li, Chang Ge, Chao Xiong, Kaichang Di, Andreas Nüchter, Levente Kovács, Qingquan Li, Shirong Ge, Fei-Yue Wang, Long Chen#
arXiv preprint arXiv:2608.21358
A structured overview of space robotics for extraterrestrial exploration, sampling, and resource extraction.
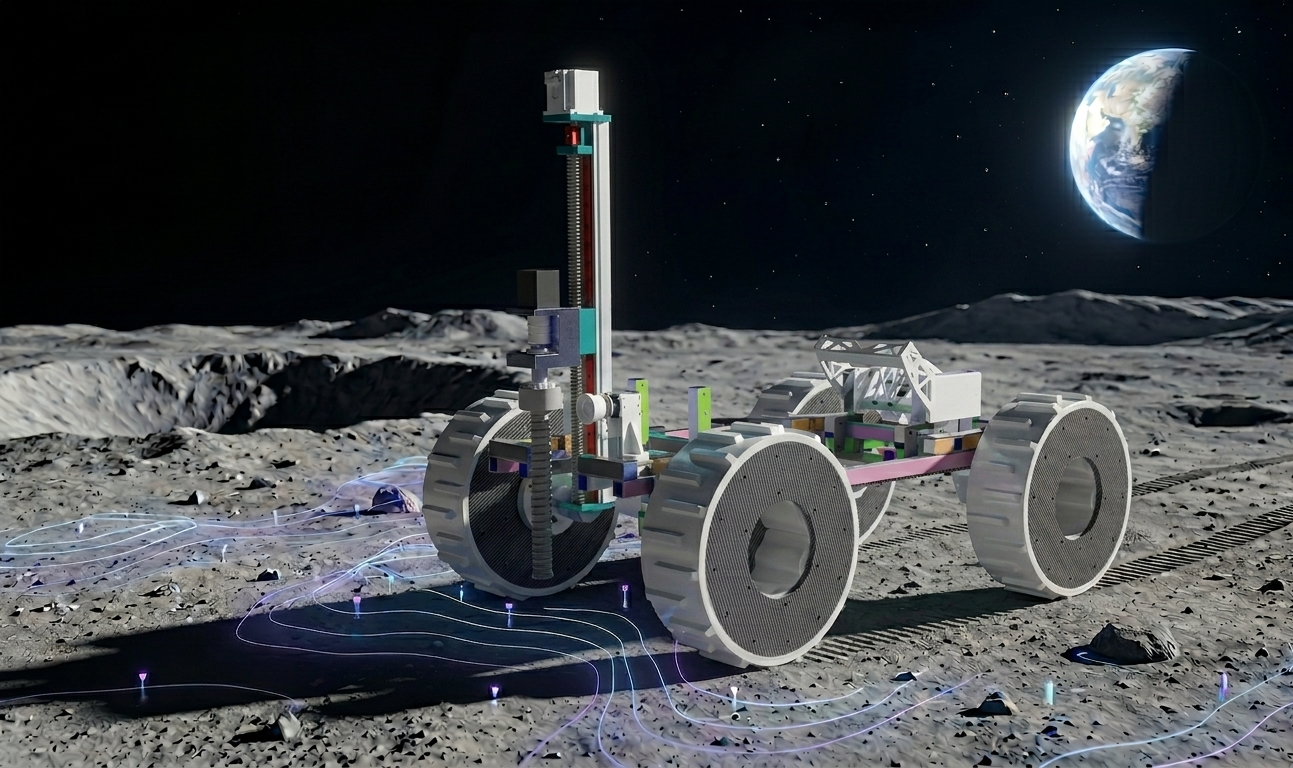
He3-Seeker: Robotic Information Planning for Lunar Helium-3 Distribution Mapping
Dong Li*, Yujie Zheng*, Chengdeng Cao, Siyu Teng, Yuchen Li, Yang Gao, Long Chen#
International Conference on Space Robotics (iSpaRo) 2026
Informative Path Planning for Dense Lunar Helium-3 Mapping via Sparse Robotic Sampling
Honors & service
Contributing to the robotics community
Selected honors
- 3rd place — Single- and Multi-Robot Tracks, indoor-exploration-competition, IROS
- IEEE RAS IROS Travel Grant
Academic service
- Organizer, IROS 2026 Special Session on Robotics for Space Exploration
- Reviewer for ICRA (9), IROS (6), iSpaRo (1), and ROMAN (1)
- Reviewer for IJRR (2), IEEE T-RO (1), RA-L (4), and TASE (5)
- Student Abstract and Poster Program Committee, AAAI-26